HKU · SAIL LAB
Intelligence that
earns our trust.
Safe Autonomy and Interactive Learning (SAIL) Lab
Advancing safe, interactive autonomy for a world shared by humans and robots.
Explore our research ↗ Meet the PI →
AUTONOMOUS DRIVING / HUMAN–AI INTERACTION/ PHYSICAL AI/ ASSISTIVE TOOLS
01 / OUR MISSION
Safe decisions. Shared environments.
Our research asks how autonomous systems can act safely when the world is uncertain and other agents are adapting. We connect planning, control and learning to study autonomy in human environments.
Led by Chen Sun at the University of Hong Kong, our work spans field robotics, autonomous driving and human-centered cyber-physical systems.
02 / RESEARCH
From interaction to assurance.
01
Social & interactive
robotics
How should robots anticipate people and navigate shared spaces? We study social navigation and proactive human–robot interaction.
PHYSICAL AI
02
Safe planning &
multi-agent systems
How can vehicles and robots coordinate under uncertainty? We investigate game-theoretic planning and safety-aware decision-making.
PLANNING & CONTROL
03
Trustworthy
autonomous intelligence
How can we understand, calibrate and build trust in AI? We explore social contracts and safety for autonomous systems.
HUMAN-CENTERED AUTONOMY
03 / PEOPLE
The people behind the research.
Exploring safe autonomy, together.
Postdocs, Visiting Scholars and Engineers
POSTDOCTORAL RESEARCHER
Zejian, DENG
POSTDOCTORAL RESEARCHER
Yong, WANG
POSTDOCTORAL RESEARCHER
Guoshun, CAI
POSTDOCTORAL RESEARCHER
Kui, ZHANG
PH.D. and M.Phil. Students
PHD Student
Jiahui, XU
PHD Student
Jiwei, TANG
PHD Student
Ruiyang, GAO
PHD Student
Yiming, SHU
PHD Student
Wei, ZHANG
PHD Student
Wenbin, MAI
PHD Student
Shengyi, LI
MPHIL
Yulun, WU
MPHIL
Zian, WANG
MPHIL
Letian, SUN
MPHIL
Junfeng, ZHANG
04 / HIGHLIGHTS
Research in focus.
Trajectory Planning | Learning-based | Safety Assurance | Energy Management | Control & Dynamics | Perception
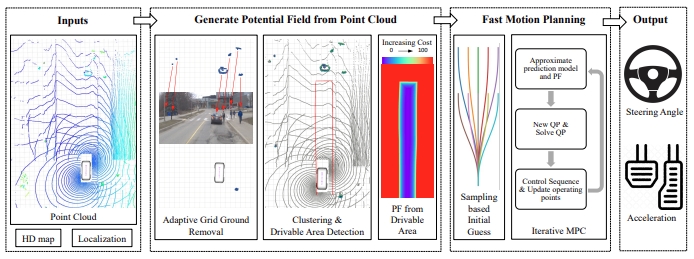
Point-Cloud Motion Planning
A Novel Motion Planning for Autonomous Vehicles Using Point Cloud Based Potential Field
Trajectory Planning
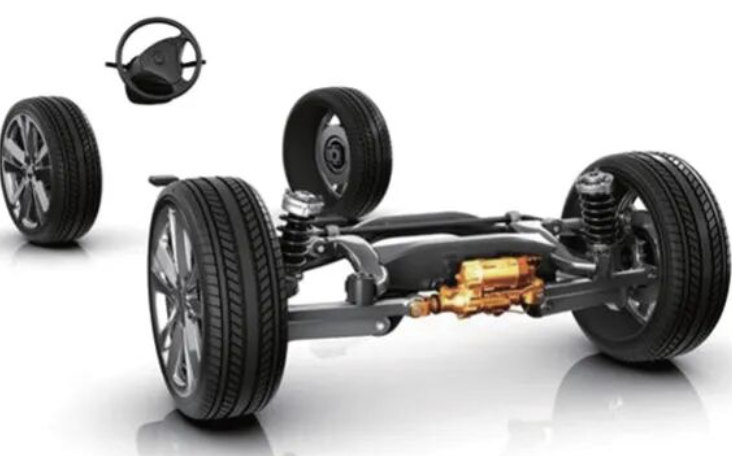
Model-Free Vehicle Control
Model-Free Control Framework for Stability and Path Tracking of Autonomous Independent-Drive Vehicles
Control & Dynamics | Trajectory Planning
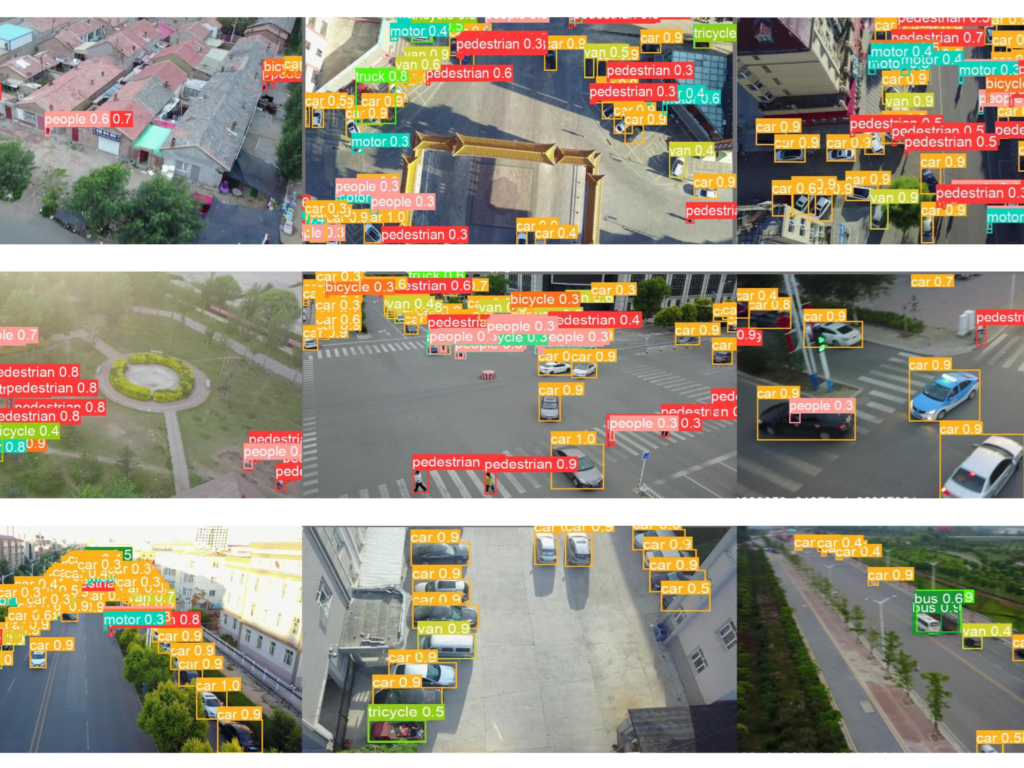
EAV-DETR with CP
EAV-DETR: Efficient Arbitrary-View oriented object detection with probabilistic guarantees for UAV imagery
Perception | Safety Assurance
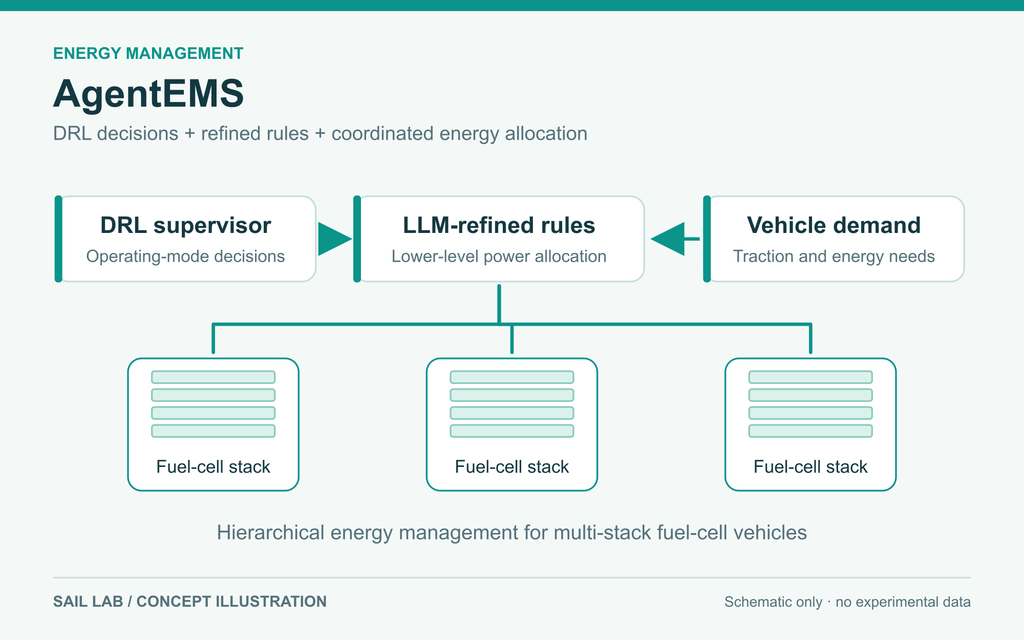
AgentEMS
AgentEMS: Integrating DRL and LLM-refined rules for hierarchical energy management of multi-stack fuel cell vehicles
Energy Management | Learning-based
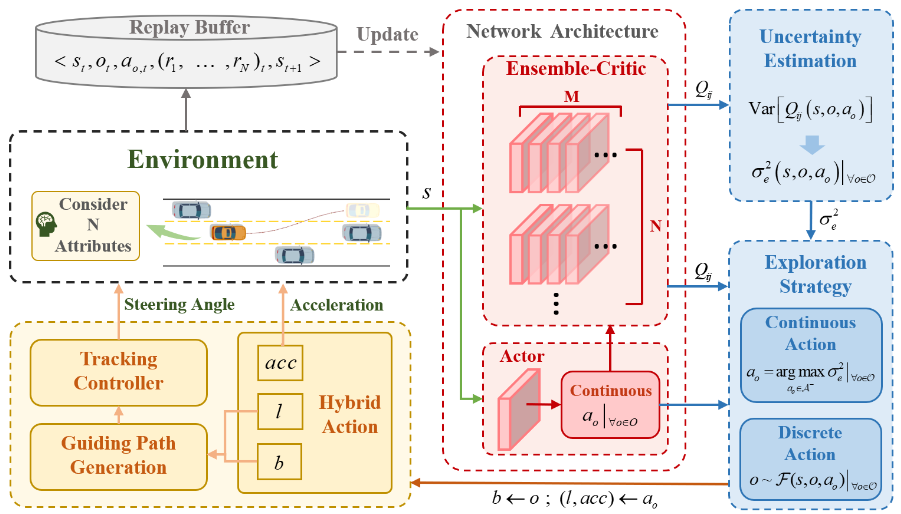
Hybrid-Action RL
Hybrid Action-Based Reinforcement Learning for Multiobjective Compatible Autonomous Driving
Learning-based | Trajectory Planning
DriveLegal
Toward Legally Compliant Driving via Trustworthy Hybrid Retrieval-Augmented LLMs
Learning-based | Safety Assurance
Fuzzy Game-Theoretic MPC
Fuzzy Game-Theoretic Tube Model Predictive Control for Integrated Vehicle Stability System
Control & Dynamics | Safety Assurance
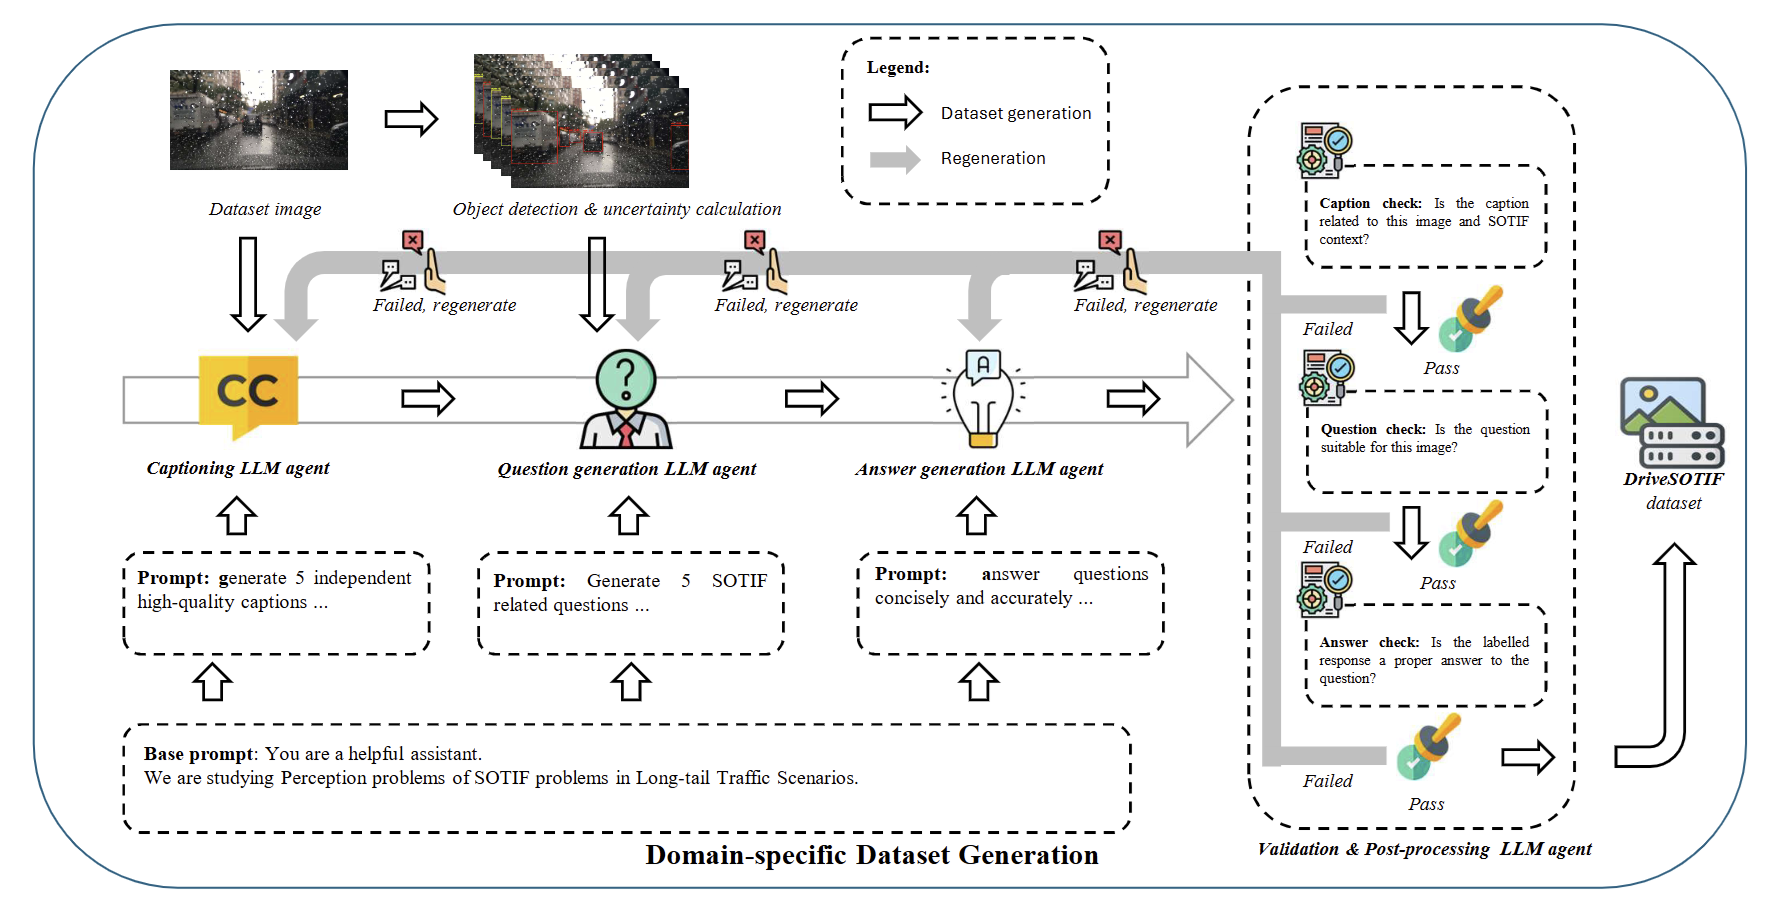
DriveSOTIF
Advancing SOTIF Through Multimodal Large Language Models
Learning-based | Safety Assurance
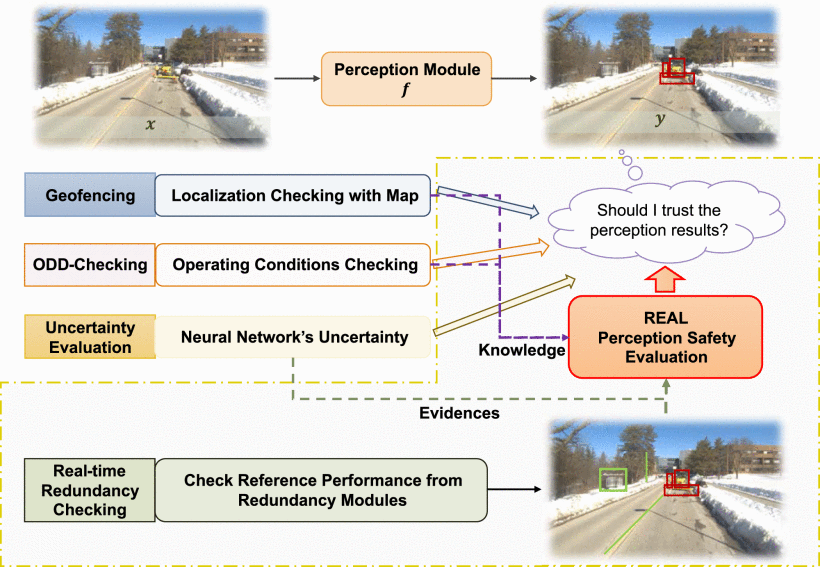
REAL-SAP
Real-Time Evidence Aware Liable Safety Assessment for Perception in Autonomous Driving
Safety Assurance
05 / NEWS
From the lab.
SEPT 2026
Congrats on Dr. Guoshun CAI on receiving Best Paper Award at 2026 IEEE-ICUS!
06 / JOIN US
Help shape safer autonomy.
Interested in research with us? Explore opportunities in world models, interactive planning and coordination of robotic systems.